Part 5/10
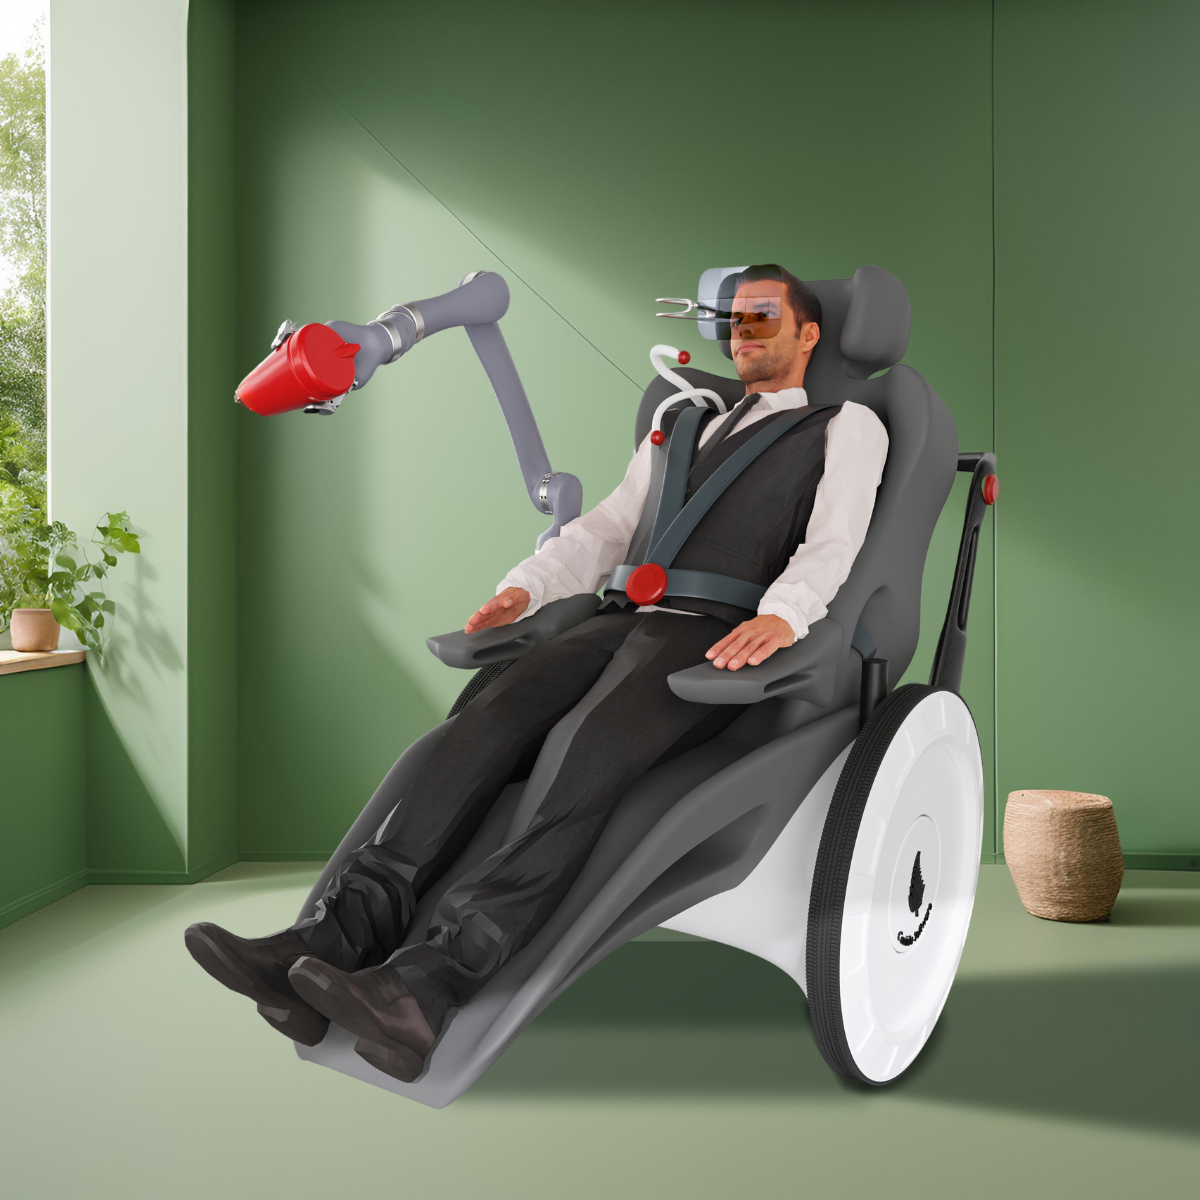
Our research project HIRAC, on which we are working together with Offenburg University of Applied Sciences, aims to help people with full-body paralysis to carry out everyday tasks independently with the help of robotic arms. In addition to image processing and object recognition, the objects must be localised in the room and the robot movements must be defined.
Using image processing and object recognition the various objects in the room are divided into categories. These categories determine which actions can be performed with the objects. However, in order to grasp the objects correctly, each object must first be localised in the room.
To localise the objects without errors, a 3D model of the environment is created with a CAD program. The subsequent localisation determines the distance to the objects in the room. In addition, surface detection can recognise surfaces that can be used for putting down objects.
To grasp the desired object, the robotic arm needs various sensors. For example, pressure sensors measure the force when lifting objects, and motion sensors monitor the surroundings during grasping movements. The robot is then able to grasp different objects in a task-specific way.
General robotic grasping is well researched and in use in industry.
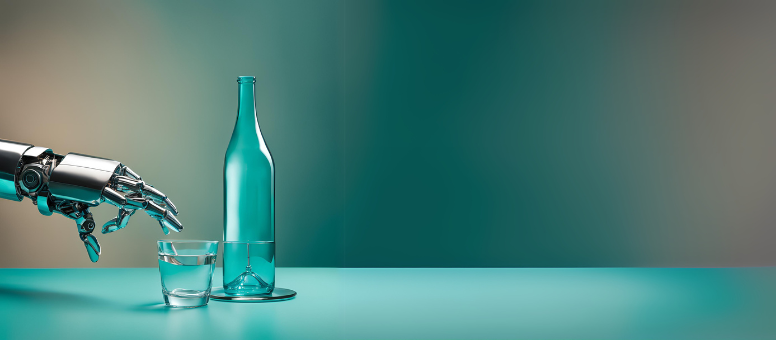
With task-specific grasping, however, the grasping process must be matched to the subsequent task. For example, a water bottle may only be grasped at certain points so that water can then be poured into a glass.
Depending on the object and the task, different movements are performed one after the other.
To make this possible without errors, different options for action must be defined for each object and the robot must be trained sufficiently.
 kununu