
Part 4/10
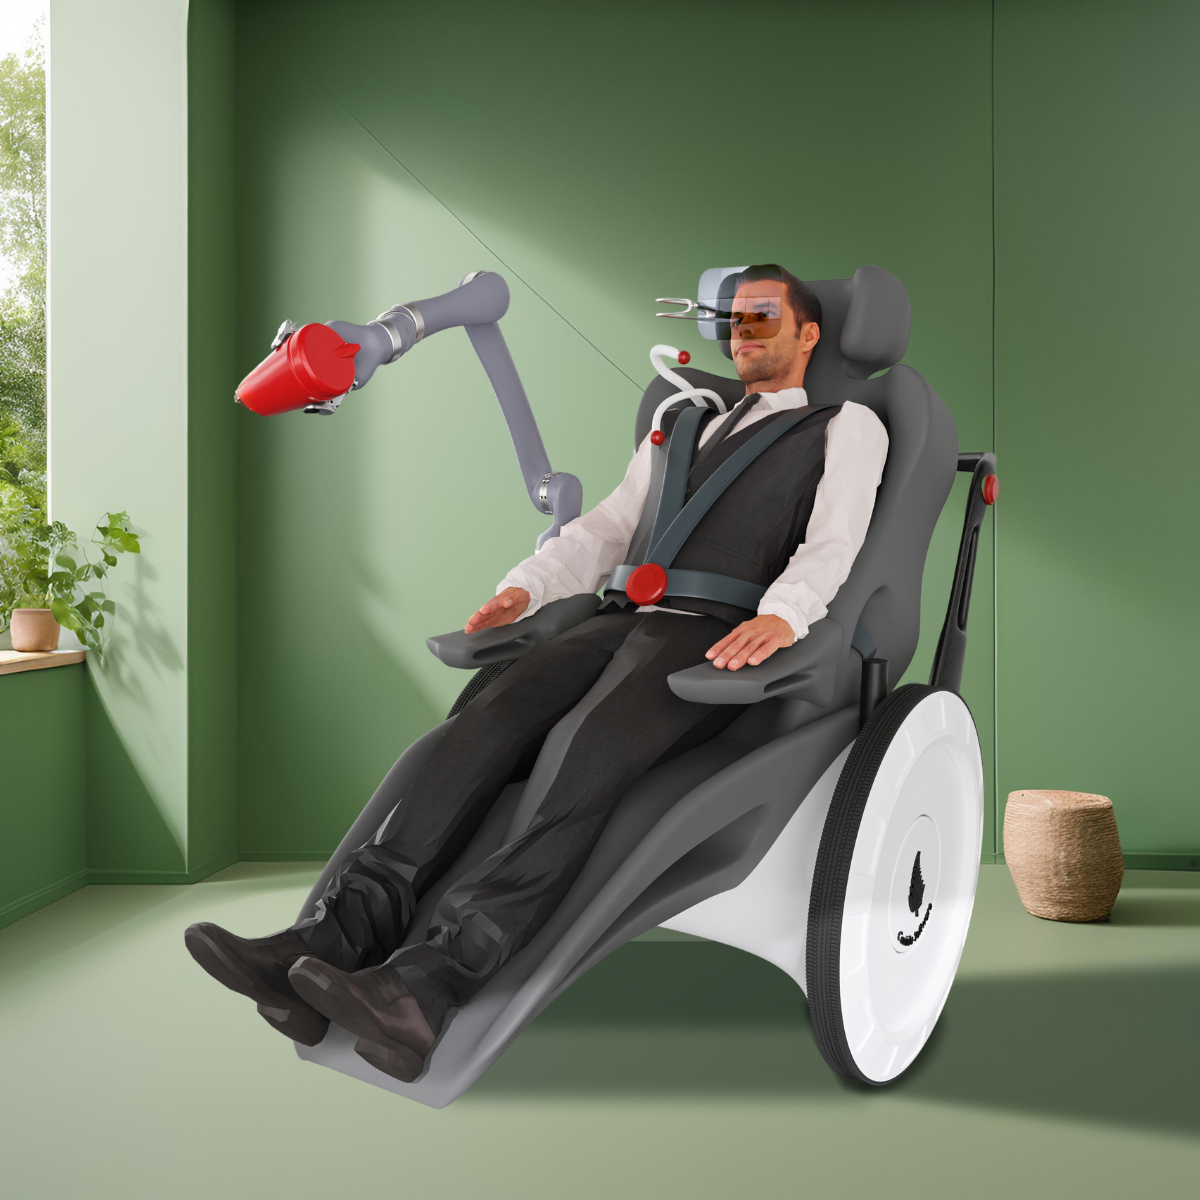
For our project, we need to develop a method that can quickly recognise and locate unknown objects in three-dimensional space. Only then can the robot arm interact with them. Our first step is therefore object recognition through image processing.
With image processing, photos and videos can also be analysed in real time. The images are read out by software and compared with sample images from a database. With the support of artificial intelligence it is possible to develop algorithms that capture and identify objects in space even faster.
In our research project, the robot's surroundings are to be recorded with a camera. Ideally, the camera should be placed on the robot. This prevents objects from being obscured by the robot arm, and the images do not become blurred. Through image processing, the camera images are evaluated and the objects can be recognised.
After the images have been evaluated, the objects must be identified by querying a database and located in space. Error-free object recognition requires environmental variables to be defined. This means, for example, that daylight or artificial lighting must be present and that the surfaces of the objects must not be highly reflective.
For optimal object recognition, sufficient data sets must be available. While large amounts of training data already exist in many areas of image recognition, the field of medical aids is heavily under-represented. We have therefore created our own data sets with assistive devices and combined existing image databases with them.
 kununu